Geometry-Guided Modeling of Foundation Features:它和通用视觉自监督的关系在于:把 foundation features 与模板拓扑、视角聚合结合,关注视觉基础特征如何承载几何泛化
中相关;详见方法、贡献和实验边界。
Geometry-Guided Modeling of Foundation Features Enables Generalizable Object Shape Deformation Learning arXiv + ICML 2026 原文链接
编号2605.29661优先级P2类别ICML 2026会议arXiv + ICML 2026方法把 foundation features 与模板拓扑、视角聚合结合,关注视觉基础特征如何承载几何泛化来源arXiv / OpenReview
先说结论。它和通用视觉自监督的关系在于:把 foundation features 与模板拓扑、视角聚合结合,关注视觉基础特征如何承载几何泛化。 中相关;详见方法、贡献和实验边界。
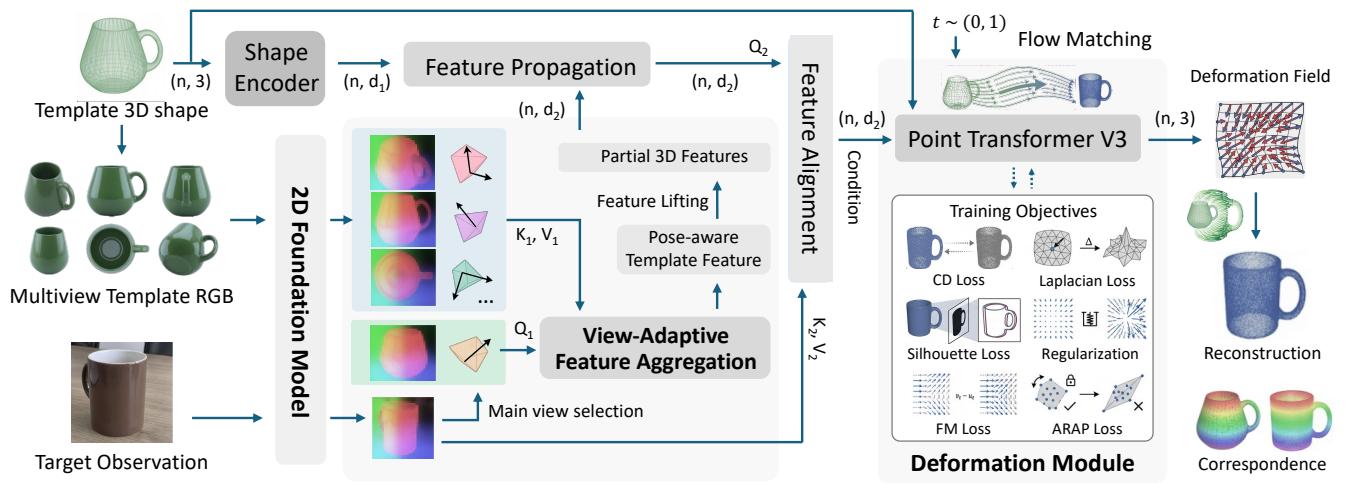
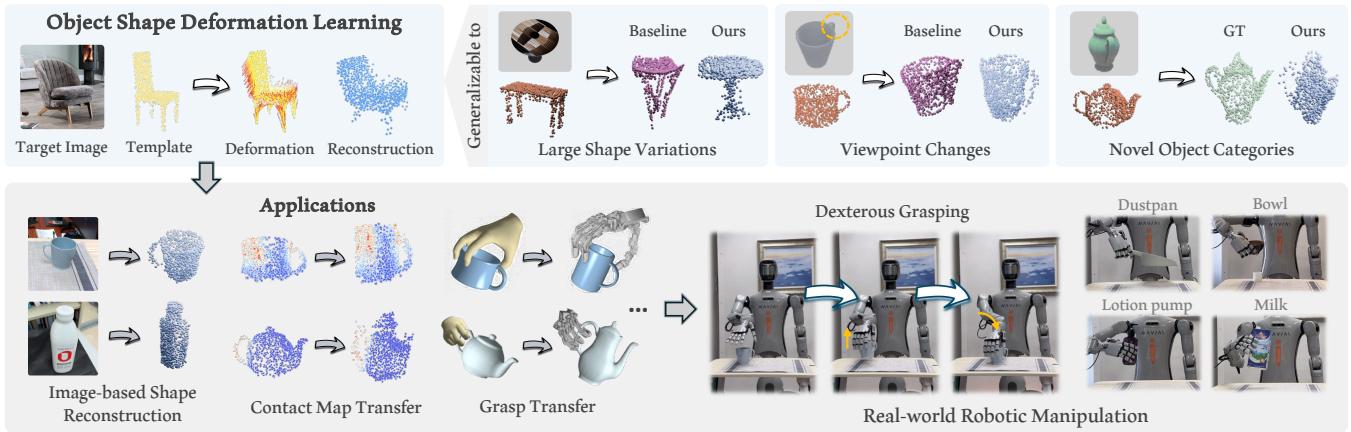
Figureure 2 · Overview of our proposed frameworkFigure 2. Overview of our proposed framework. The core of our approach is a conditional flow-matching module that warps a template shape toward a target via a continuous trajectory. This deformation is conditioned on the geometry-guided modeling of 2D foundation features. To ensure these features are spatially aligned and robust to varying observation angles, we introduce two key components: (1) a geometry-guided feature modeling process, which diffuses lifted 2D features across the 3D template surface to bridge the domain gap; and (2) a view-adaptive feature aggregation module, which synthesizes a pose-aware, viewpoint-invariant feature map to compensate for self-occlusions.这张图概括 Geometry-Guided Modeling of Foundation Features 的整体方法流程。阅读时先看模块之间传递的训练信号,再看作者如何把目标拆成可优化的子问题。Figureure 1 · The proposed object shape deformation learning framework can handle laFigure 1. The proposed object shape deformation learning framework can handle large template-target shape variations, remains robust to diverse camera viewpoints, and generalizes to unseen categories. It enables various downstream applications, and effectively supports generalizable dexterous robotic manipulation in the real world.这张图概括 Geometry-Guided Modeling of Foundation Features 的整体方法流程。阅读时先看模块之间传递的训练信号,再看作者如何把目标拆成可优化的子问题。
核心问题
它和通用视觉自监督的关系在于:把 foundation features 与模板拓扑、视角聚合结合,关注视觉基础特征如何承载几何泛化。
方法拆解
把 foundation features 与模板拓扑、视角聚合结合,关注视觉基础特征如何承载几何泛化