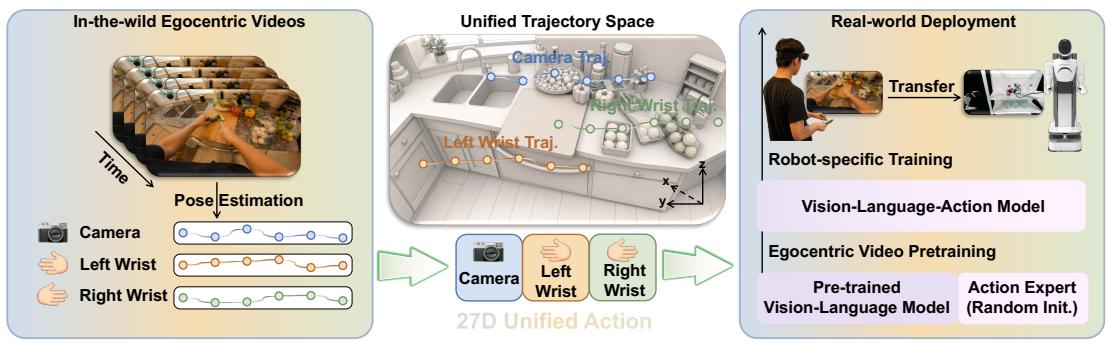
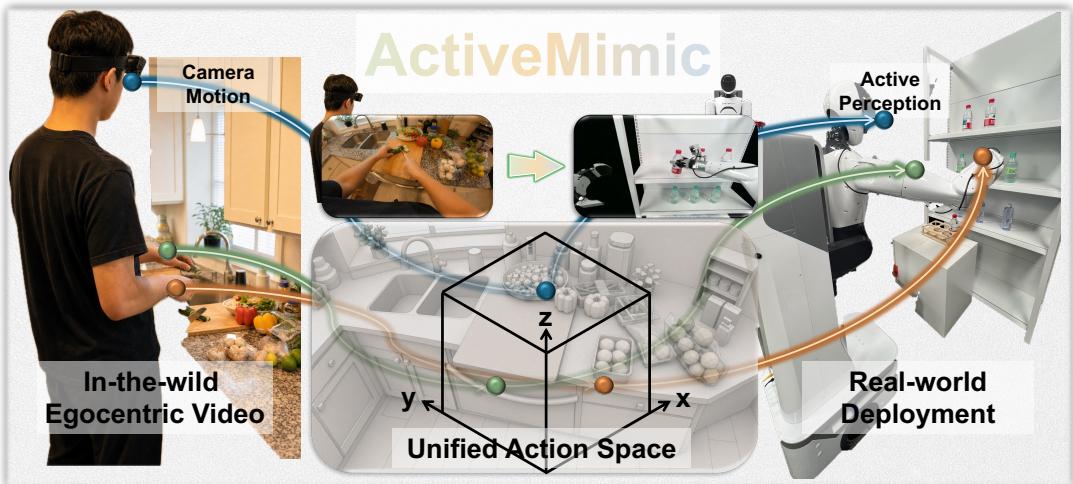
Figureure 2 · : Overview of ActiveMimicFigure 2: Overview of ActiveMimic. Left: recovering synchronized camera and wrist trajectories from a single body-worn RGB camera. Middle: resolving camera-wrist coupling and encoding as a unified 27D action. Right: pretraining on the 27D action to jointly model active perception and manipulation, then adapting to the target robot.这张图概括 ActiveMimic 的整体方法流程。阅读时先看模块之间传递的训练信号,再看作者如何把目标拆成可优化的子问题。Figureure 1 · : ActiveMimic acquires active perception from in-the-wild egocentric hFigure 1: ActiveMimic acquires active perception from in-the-wild egocentric human video and transfers it to real-world humanoid robots. Left to center: egocentric camera motion and wrist action together form a 27-dimensional unified action representation that enables the model to jointly learn active perception and manipulation. Center to right: active perception is transferred to a humanoid robot, which repositions its viewpoint actively during task execution.这张图来自论文 PDF 的结构化抽取。当前用于辅助理解 ActiveMimic 的方法或实验,请结合正文精读段落一起看。