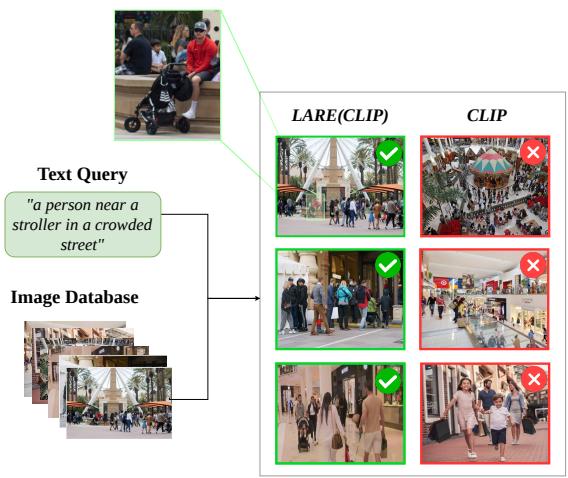
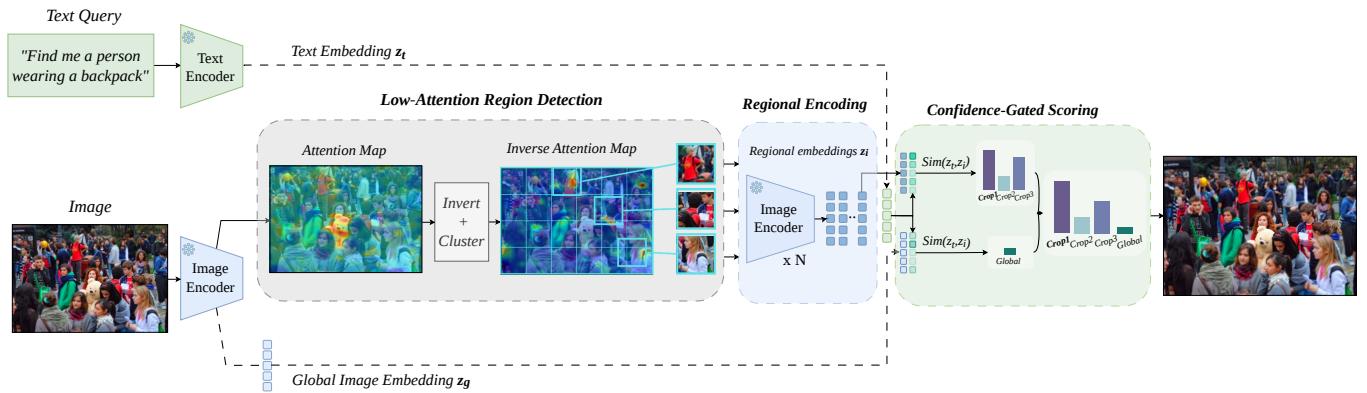
Figureure 1 · Fine-grained retrieval in dense scenesFigure 1. Fine-grained retrieval in dense scenes. For the query “a person near a stroller in a crowded street”, LARE retrieves results that preserve the stroller-related local cue, while CLIP tends to favor globally similar crowded scenes. Green checks indicate relevant matches; red crosses indicate mismatches.这张图/表用于判断 LARE 的实验收益来自哪里。重点看替换、消融或跨模型设置下趋势是否一致,而不是只看单个最高分。Figureure 3 · LARE pipeline: A single forward pass produces both a global image embeFigure 3. LARE pipeline: A single forward pass produces both a global image embedding and a spatial attention map. Inverting the attention map highlights under-attended regions, which are clustered into candidate crops and then re-encoded independently. A confidence gate determines whether regional evidence should be used to adjust the final retrieval score.这张图概括 LARE 的整体方法流程。阅读时先看模块之间传递的训练信号,再看作者如何把目标拆成可优化的子问题。