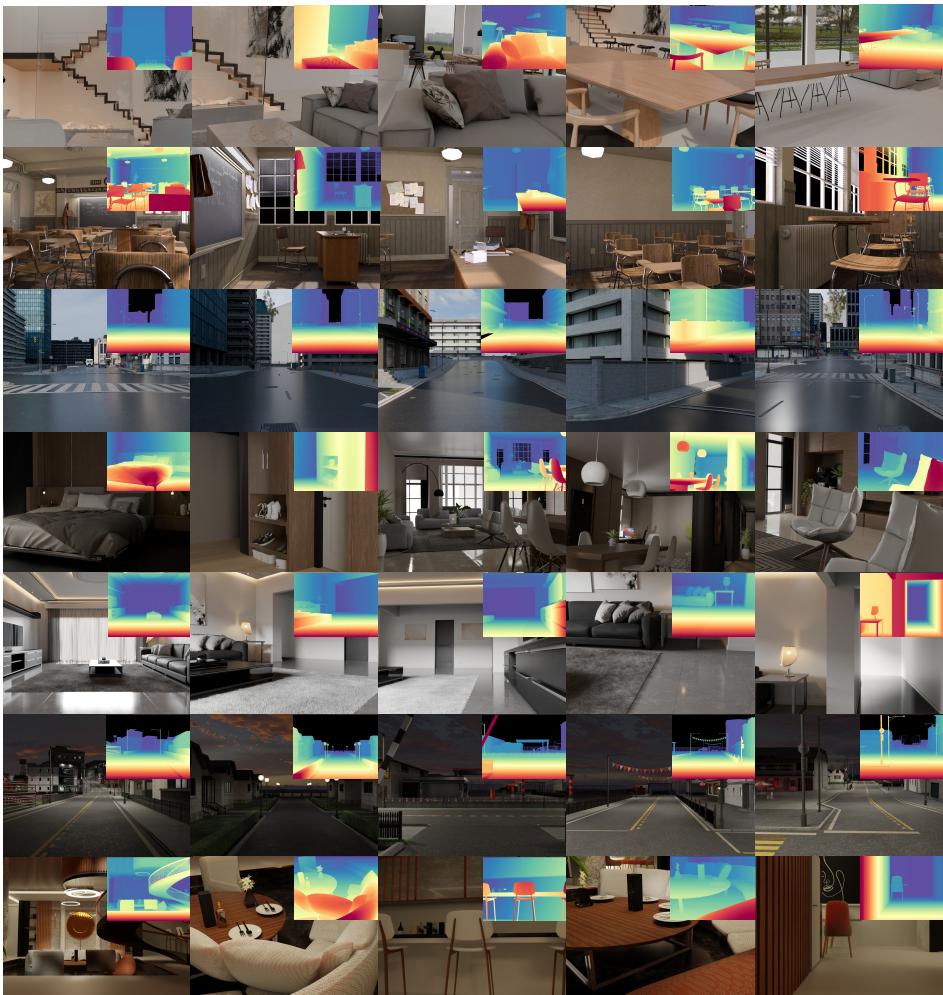
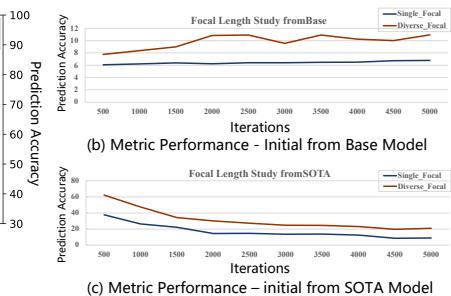
Figureure 7 · : Overview of the FoundationGeo DatasetFig. 7: Overview of the FoundationGeo Dataset. We build a Blender-based synthetic data engine with seven scenes, including five indoor scenes and two outdoor scenes. The figure shows representative RGB images and corresponding depth maps from each scene, illustrating the diversity of layouts, viewpoints, and geometric structures covered by the dataset.这张图概括 FoundationGeo 的整体方法流程。阅读时先看模块之间传递的训练信号,再看作者如何把目标拆成可优化的子问题。Figureure 4 · : (a) Training focal distribution (top-50 frequent values) vsFig. 4: (a) Training focal distribution (top-50 frequent values) vs. benchmark performance. (b)(c) Controlled Blender fine-tuning with Single-Focal vs. Diverse-Focal for (b) our base model and (c) a pre-trained metric model.这张图/表用于判断 FoundationGeo 的实验收益来自哪里。重点看替换、消融或跨模型设置下趋势是否一致,而不是只看单个最高分。
核心问题
它和通用视觉自监督的关系在于:以 DINOv3 初始化几何 foundation model,关注跨域 metric geometry 和 pixel-wise field。
方法拆解
以 DINOv3 初始化几何 foundation model,关注跨域 metric geometry 和 pixel-wise field